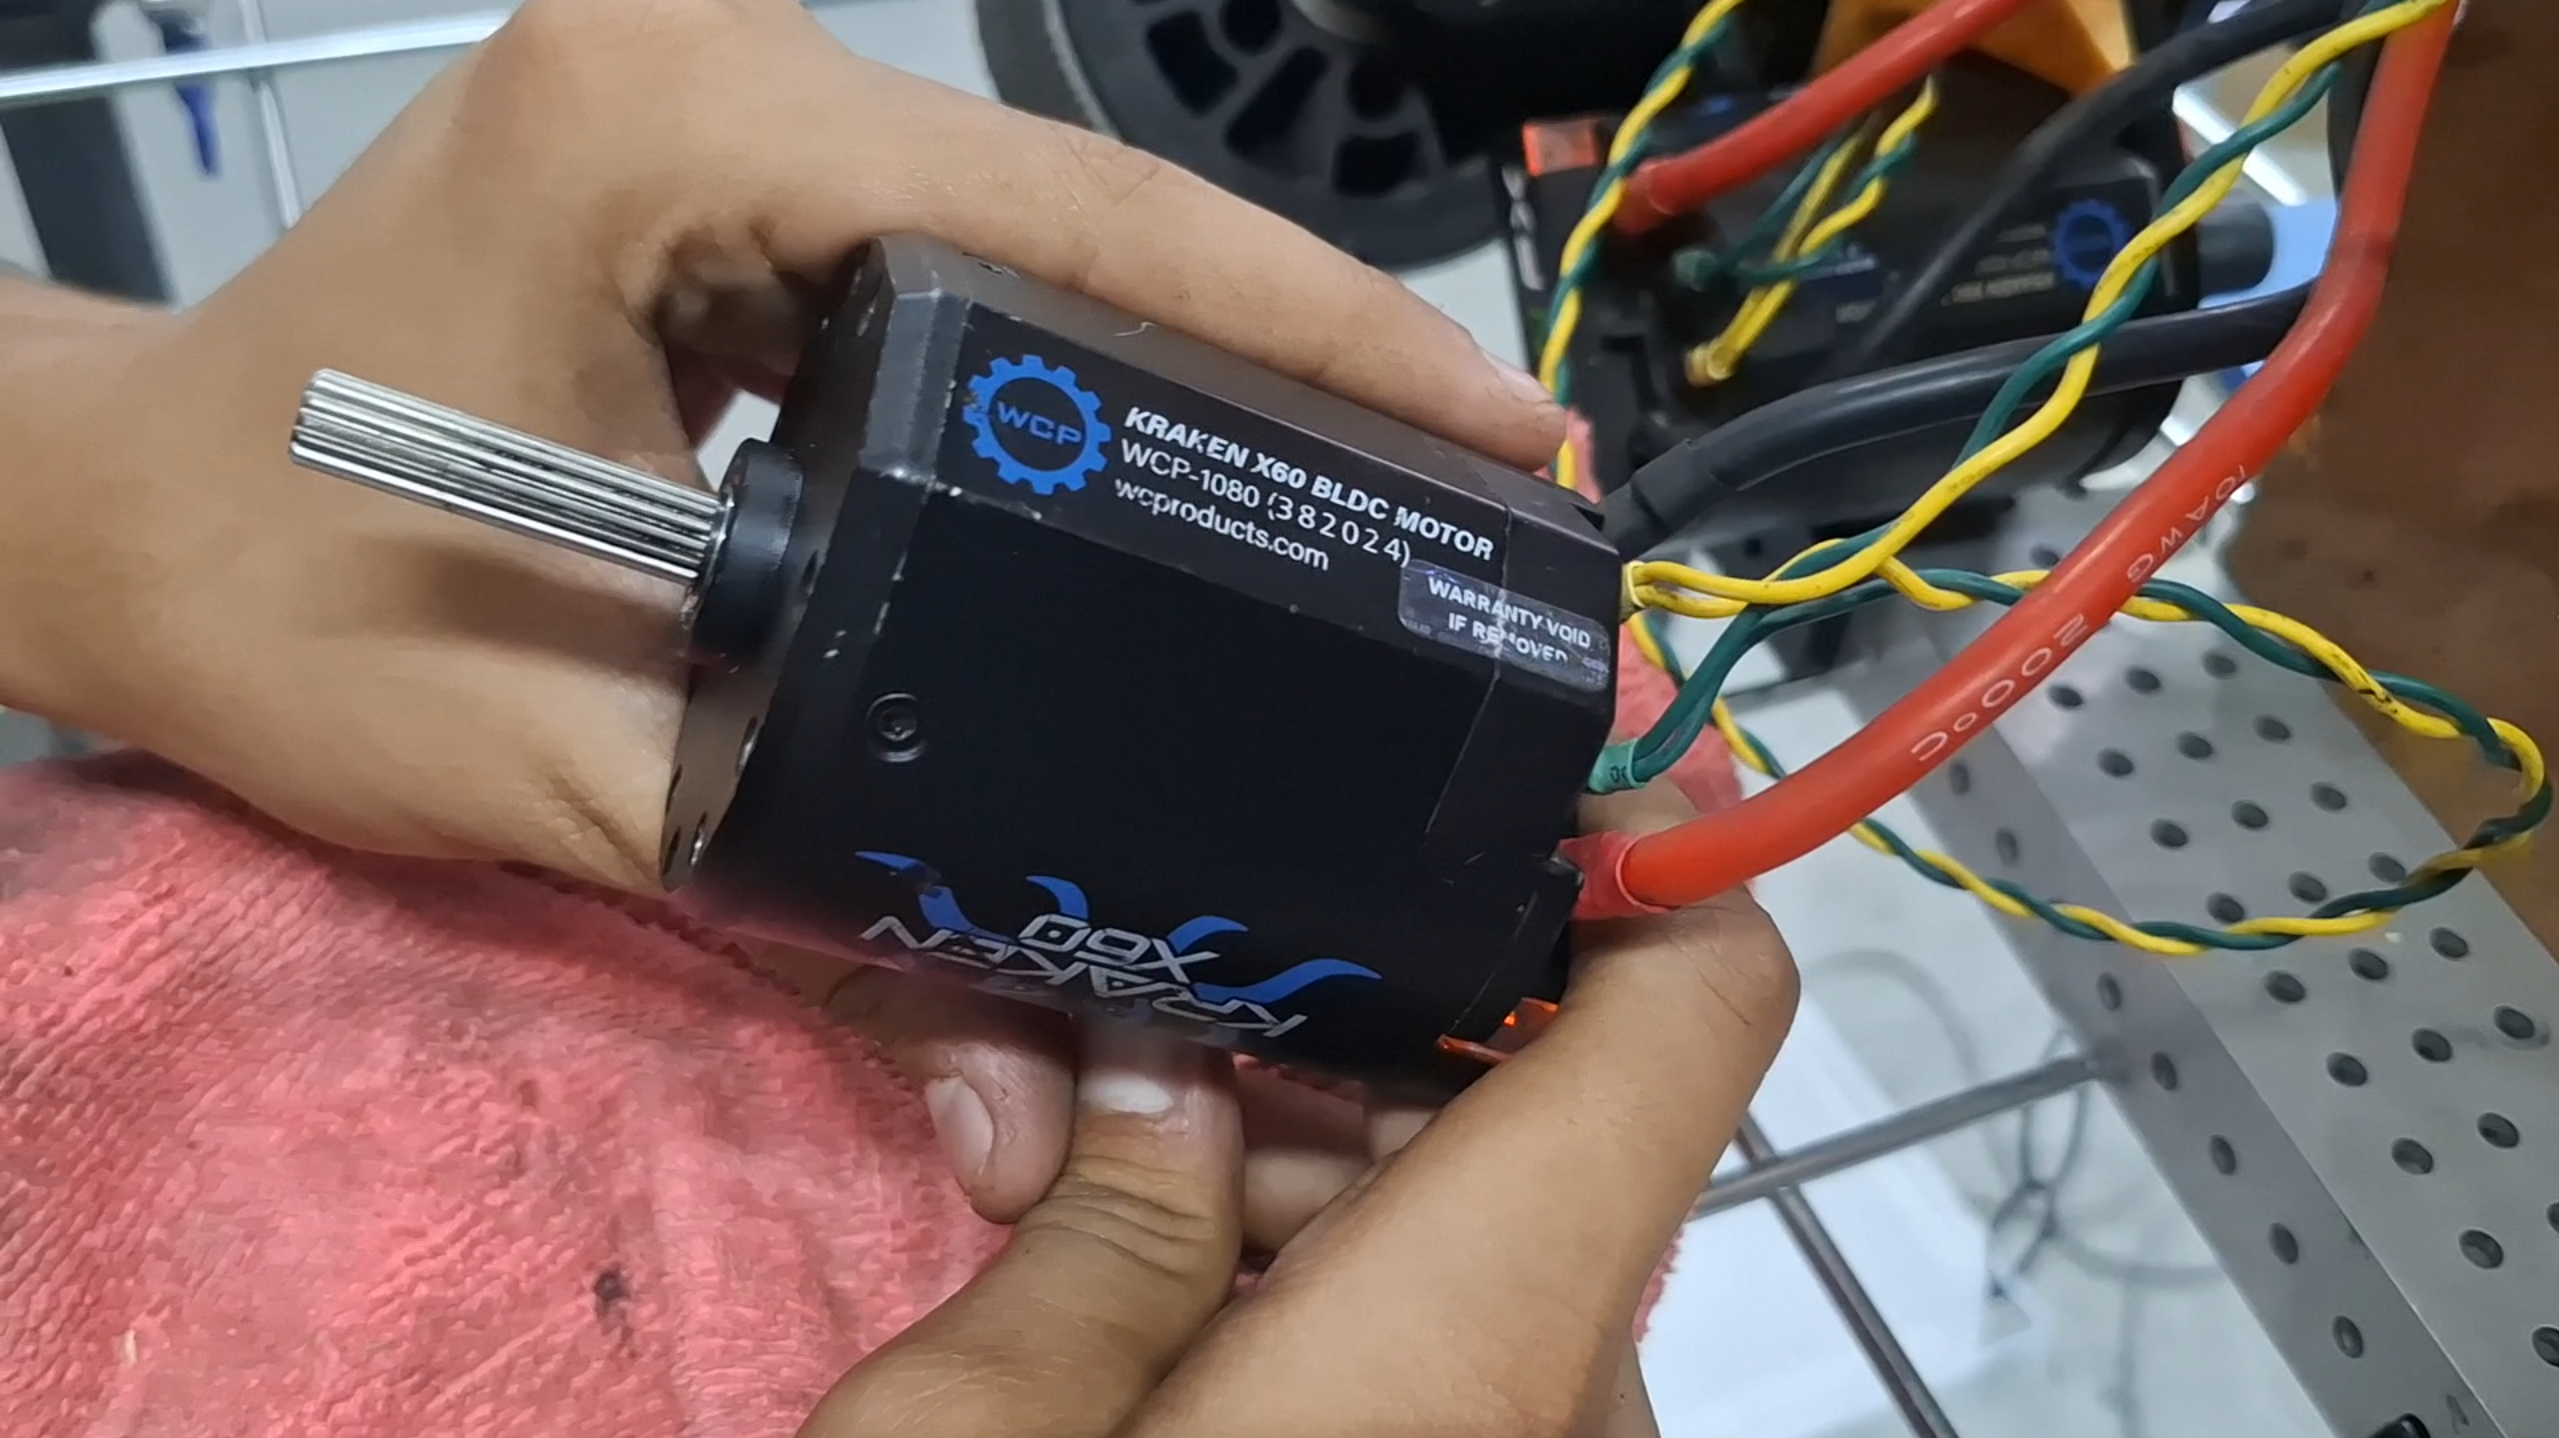
The Kraken X60 is a high-power brushless motor built for the rigors of the FIRST® Robotics Competition, advanced hobbyists, and high-performance professional robotics applications such as industrial automation. Featuring 1,108W peak power, 87% max efficiency, and 7.09Nm stall torque, it integrates CTR Electronics’ advanced Talon FX™ motor controller for precise onboard motion control. With a durable SplineXS shaft, built-in encoder, and full compatibility with the CTR Electronics ecosystem, it’s engineered for reliability, integration, and top-tier control across both competition fields and industrial environments. Assembled and QA tested at CTRE HQ in Michigan.
— Quoted from CTR Electronics
The Kraken X60 was our main choice for the subsystems of our 2026 robot, Pegasus. It offered a balance of power, efficiency, and reliability. Unfortunately, during the season, we ran into issues with two motors: one had winding issues, while the other appeared to have a blown MOSFET, which subsequently caused the driver to fail as well. We were able to contact WCP/CTRE for support; however, due to the international nature of our team, an RMA wasn’t possible. Since we had already ordered new motors, we decided to disassemble the failed ones ourselves to find out what went wrong.
Disclaimer: The following is a technical analysis of the Kraken X60 motors. It is based on our own observations and experiences and may not reflect the official specifications or recommendations from CTR Electronics. The motors shown in the images will never be used on a competition FRC robot and will remain as exhibit pieces. WE DO NOT RECOMMEND REPLICATING WHAT WE ARE DOING IN THIS POST. THIS POST IS FOR EDUCATIONAL PURPOSES ONLY AND SHOWS A RARE SCENARIO THAT DOES NOT REFLECT THE NORMAL BEHAVIOR OF THESE MOTORS. WE HAVE NOT BEEN ABLE TO CONFIRM 100% WHAT CAUSED THE DAMAGE TO THE MOTORS, SO THE FOLLOWING IS ONLY A HYPOTHESIS.
The Talon FX™ motor controller
The Talon FX™ motor controller is the primary motor controller for the Kraken X60.
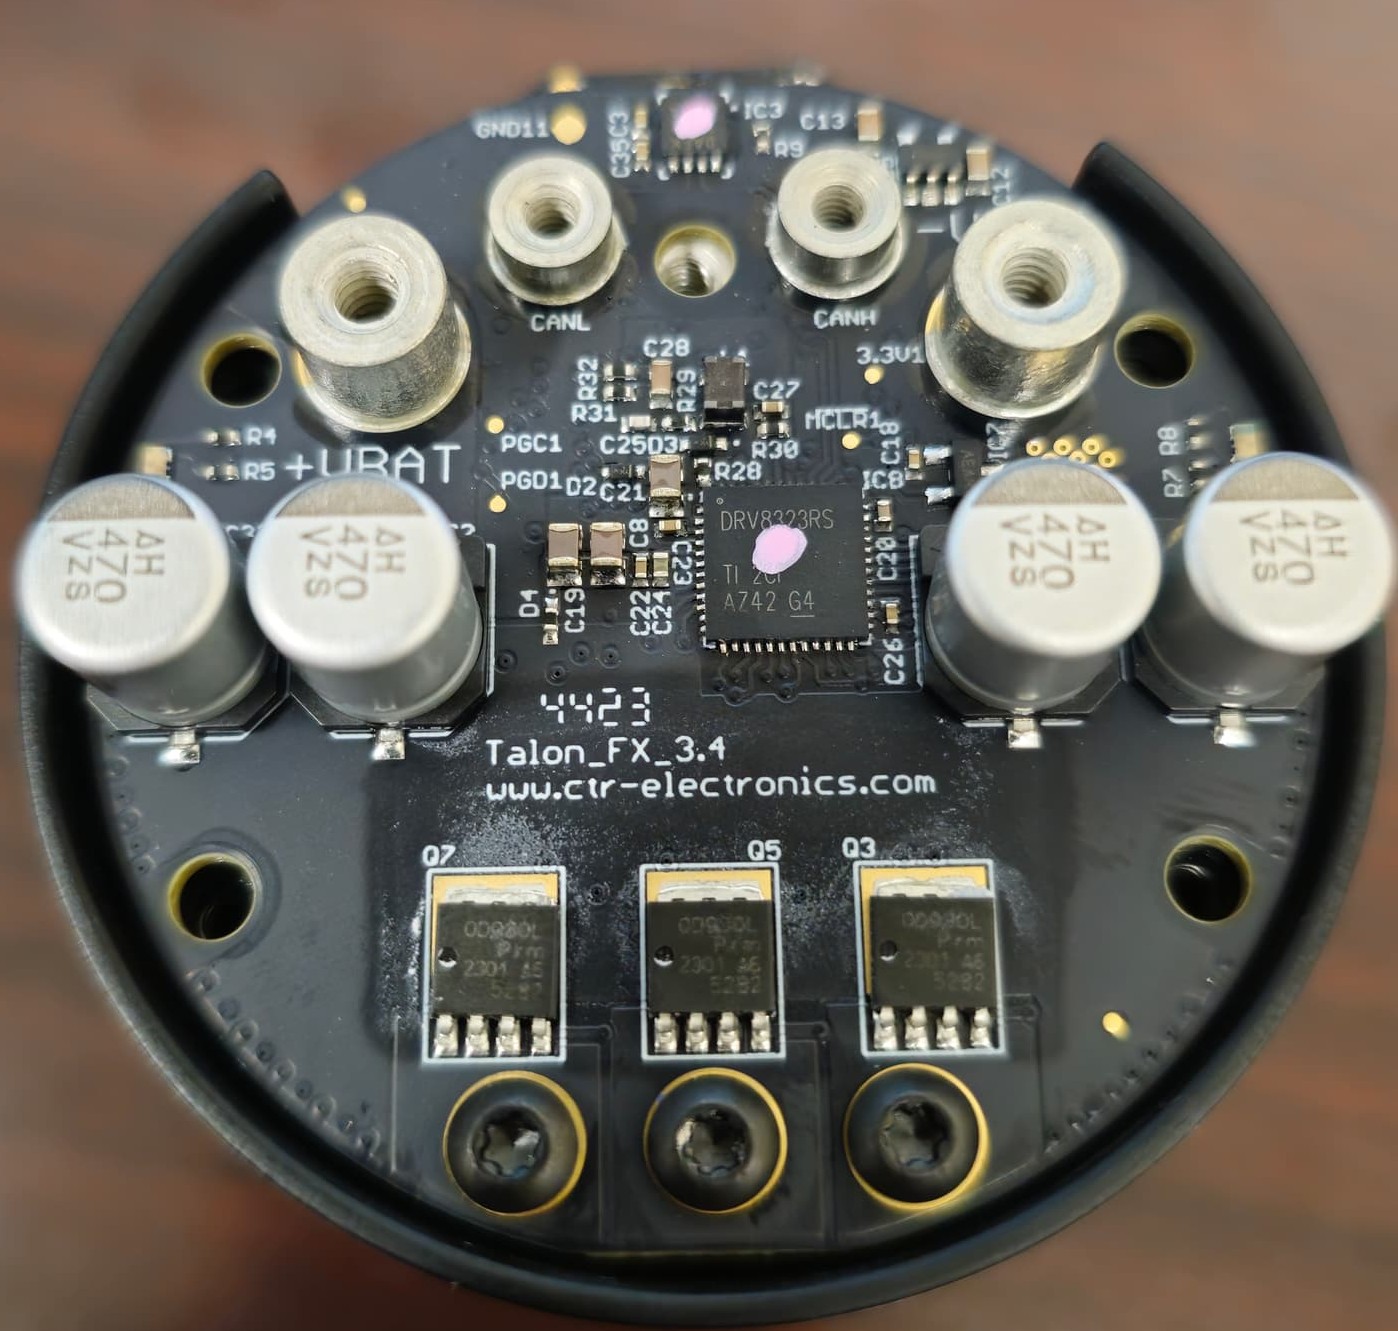
On the front, we can see three OD930L MOSFETs and a DRV8323RS gate driver that controls the high-side and low-side MOSFETs supplying power to the motor phases.
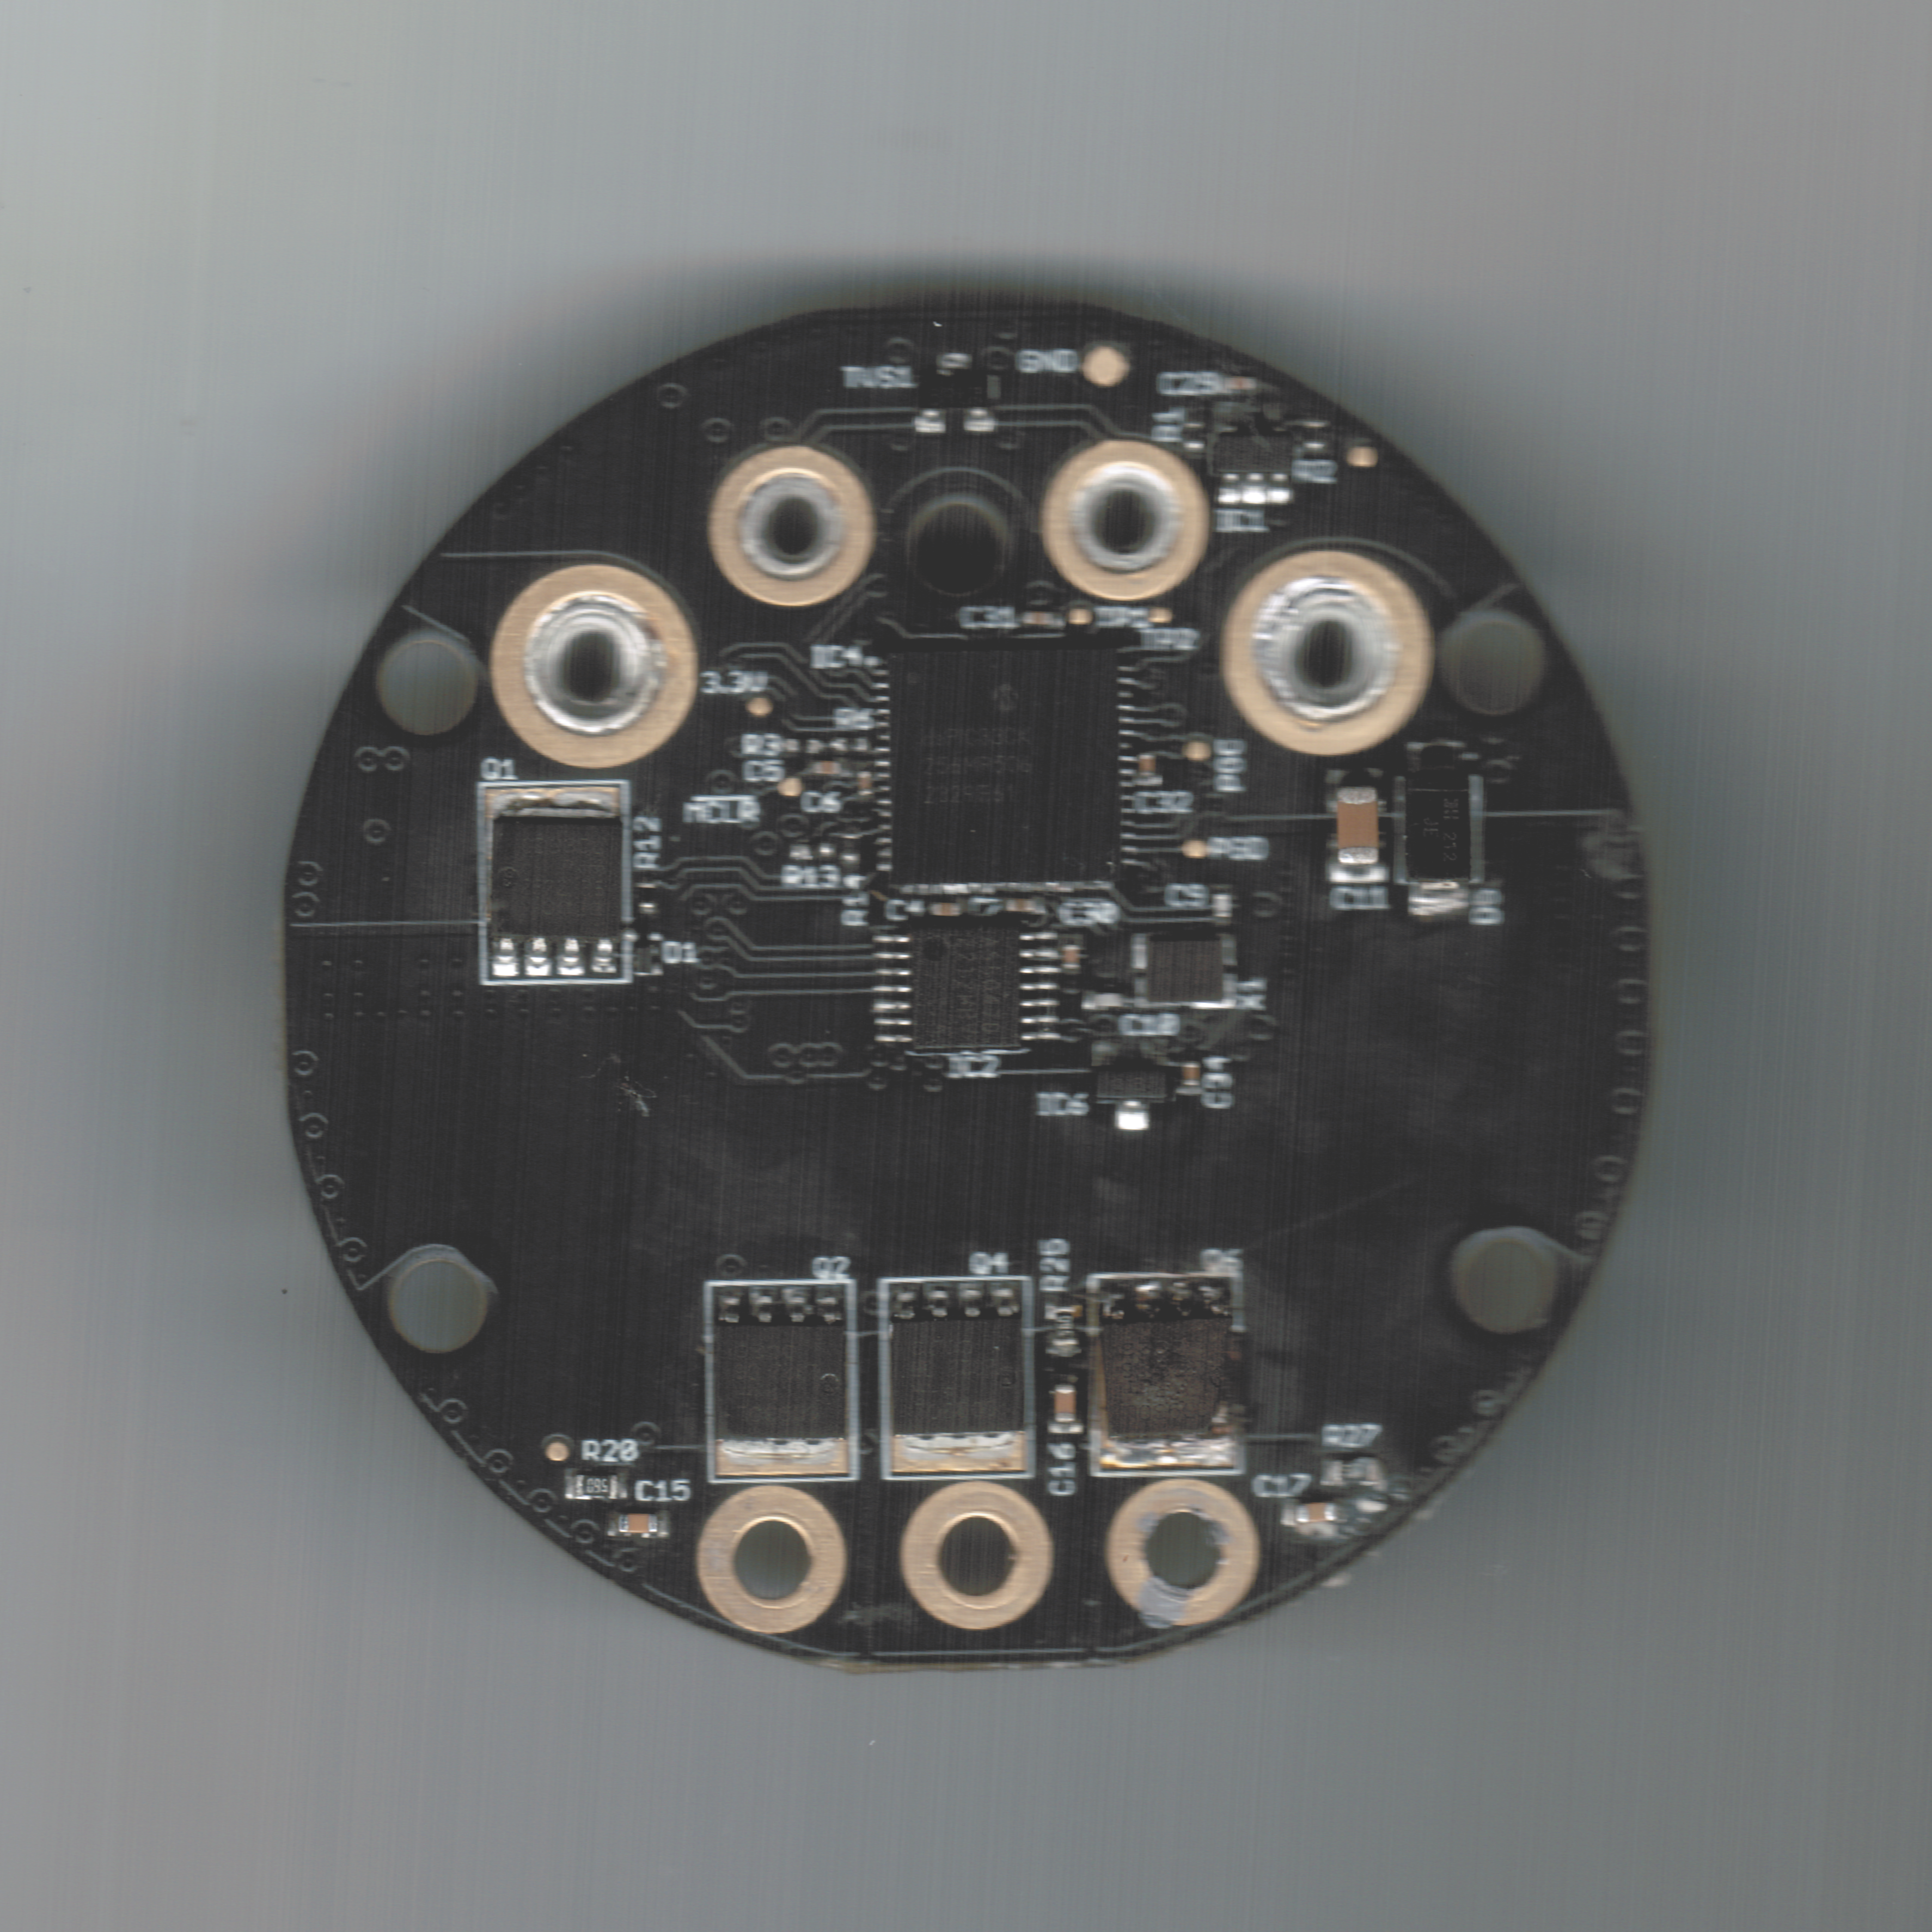
On the back, we can see the other four OD930L MOSFETs: one serves as reverse-polarity protection (Q1), while the other three complete the inverter bridge. We can also see a 16-bit, 100 MHz dsPIC33CK256MP506 microcontroller with 256 KB of flash memory that runs the control algorithms, PID loops, and CAN communication stack, along with the AS5047D 14-bit magnetic encoder that provides the Kraken with precise position and velocity feedback.
But why did the motor fail?
We are not experts in electronics, but we were able to narrow down some possible causes. When we opened the motor, we found that a MOSFET had lifted from the board. This could have been caused by a short circuit or an overcurrent condition, although that would be very unusual considering that these MOSFETs are designed to handle much more current than the wiring could withstand.
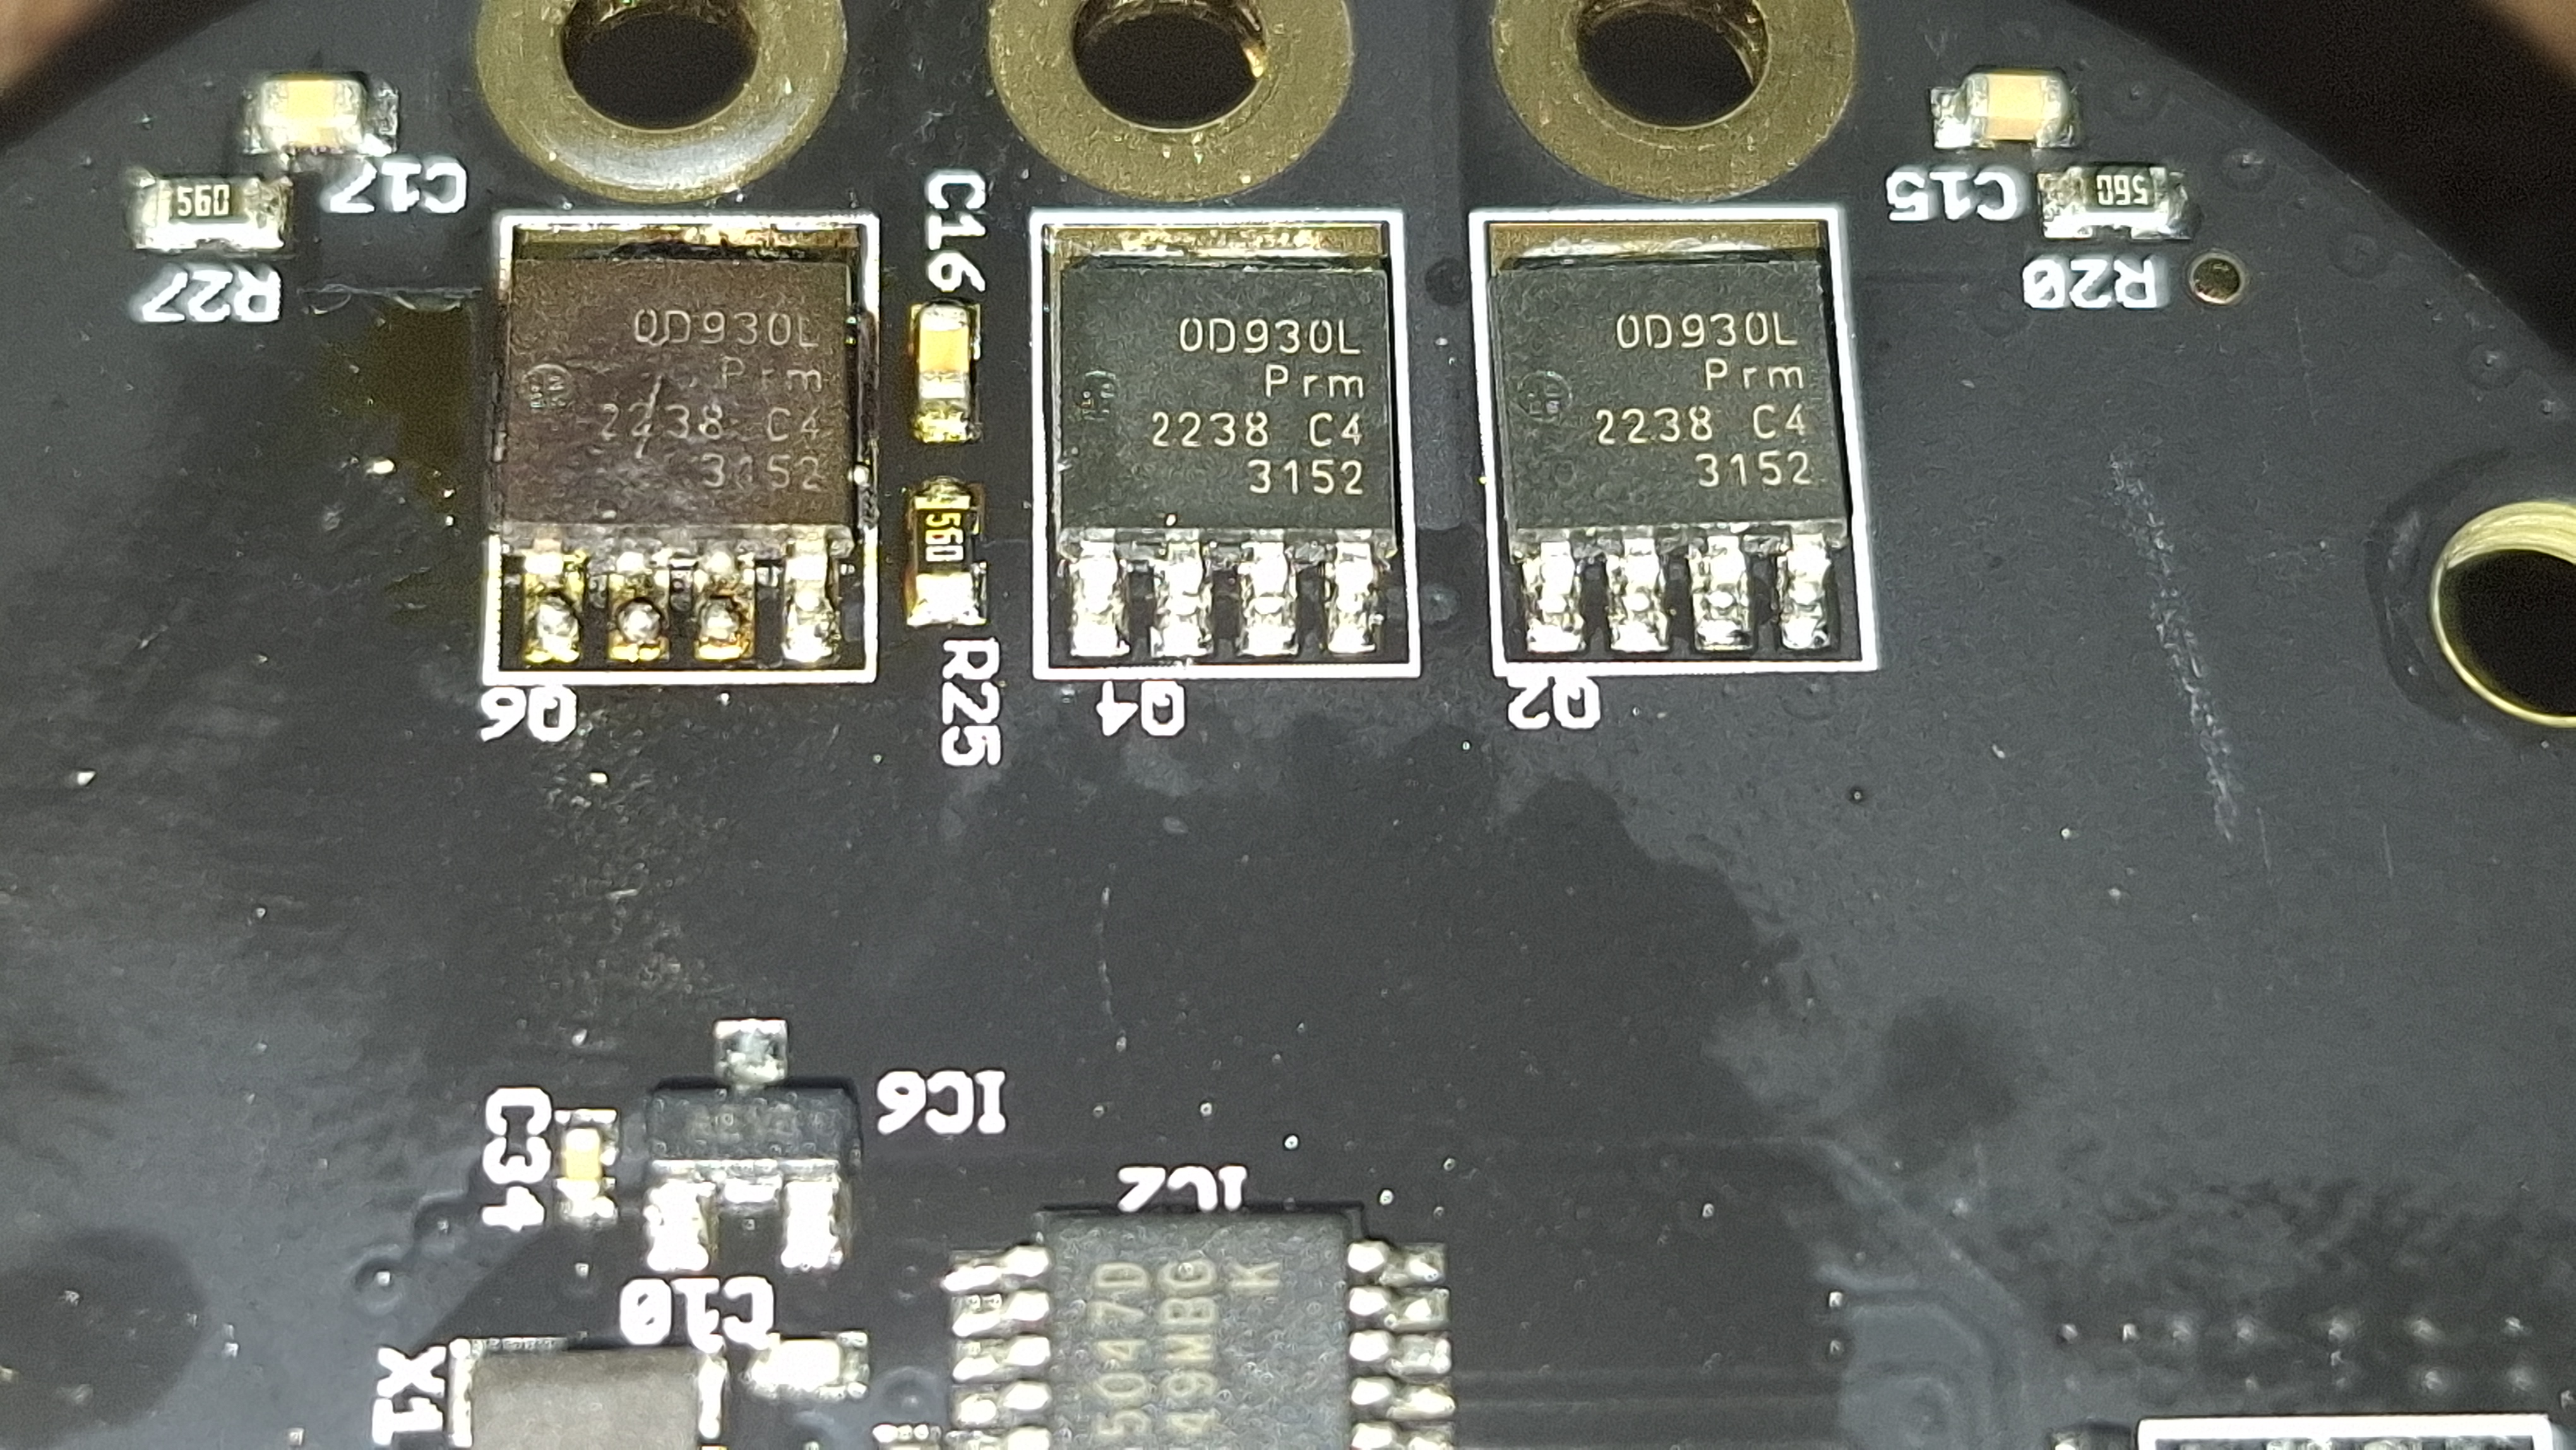
After a closer look, the MOSFET itself appeared to be fine, but its solder joint had lifted from the board, and the MOSFET had residue indicating exposure to high temperatures.
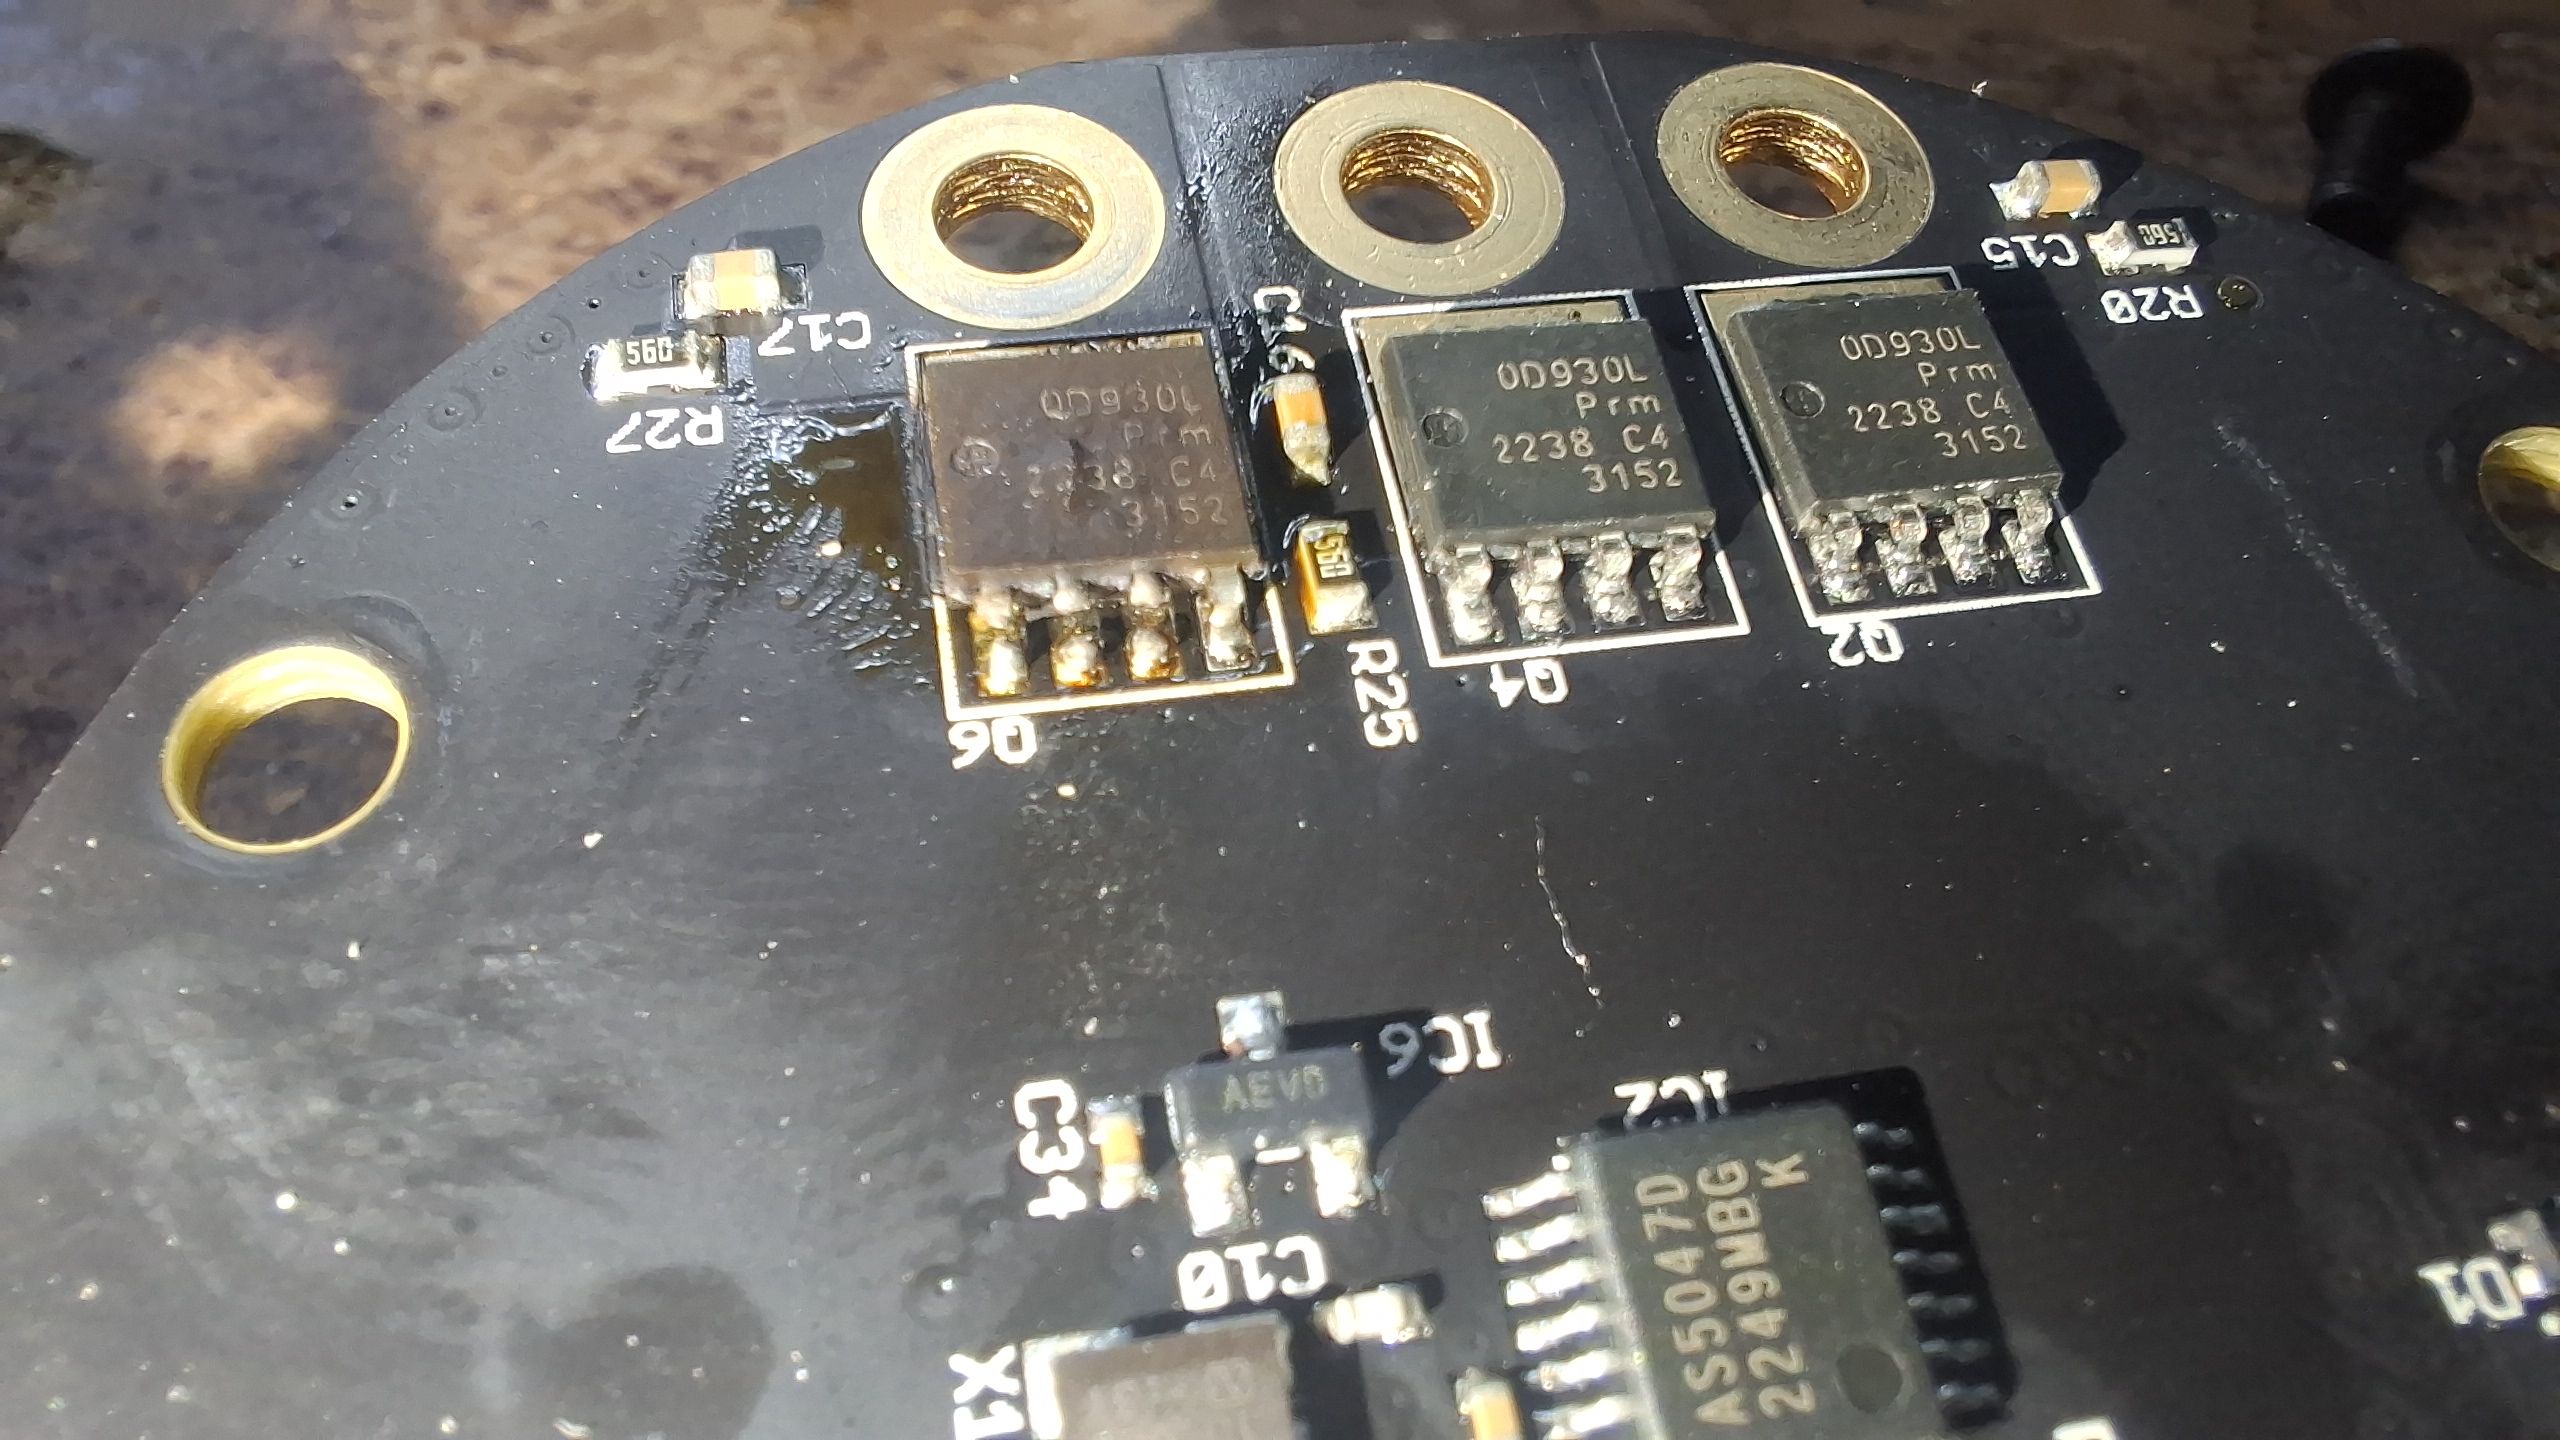
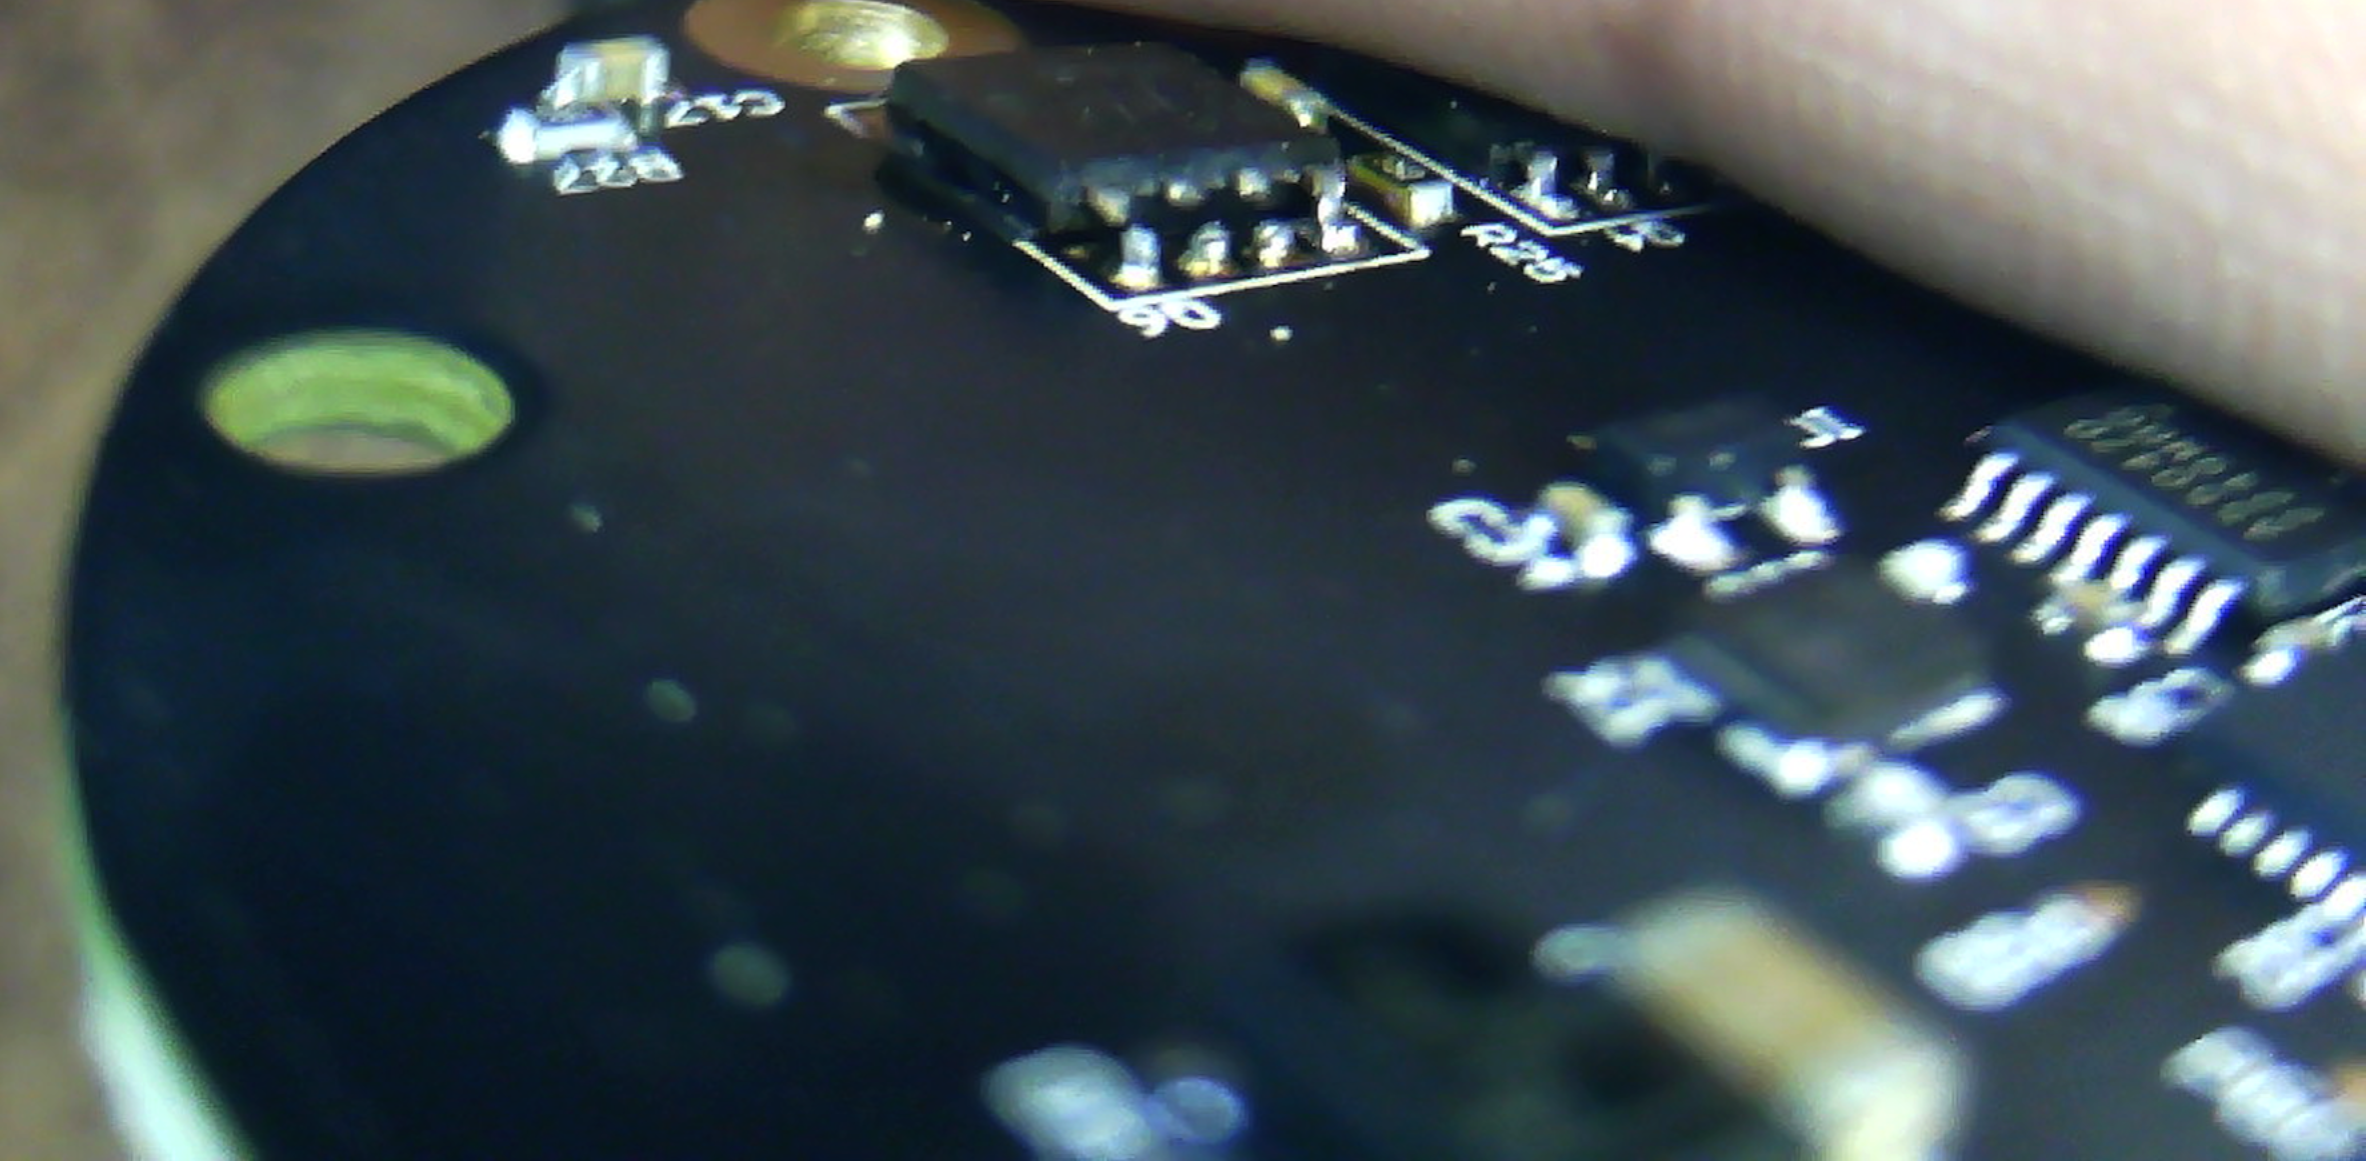
We tested the MOSFET and concluded that it had an internal short, which subsequently caused the high-temperature event that lifted it from the board.
At the time, we didn’t realize that the gate driver had also failed.
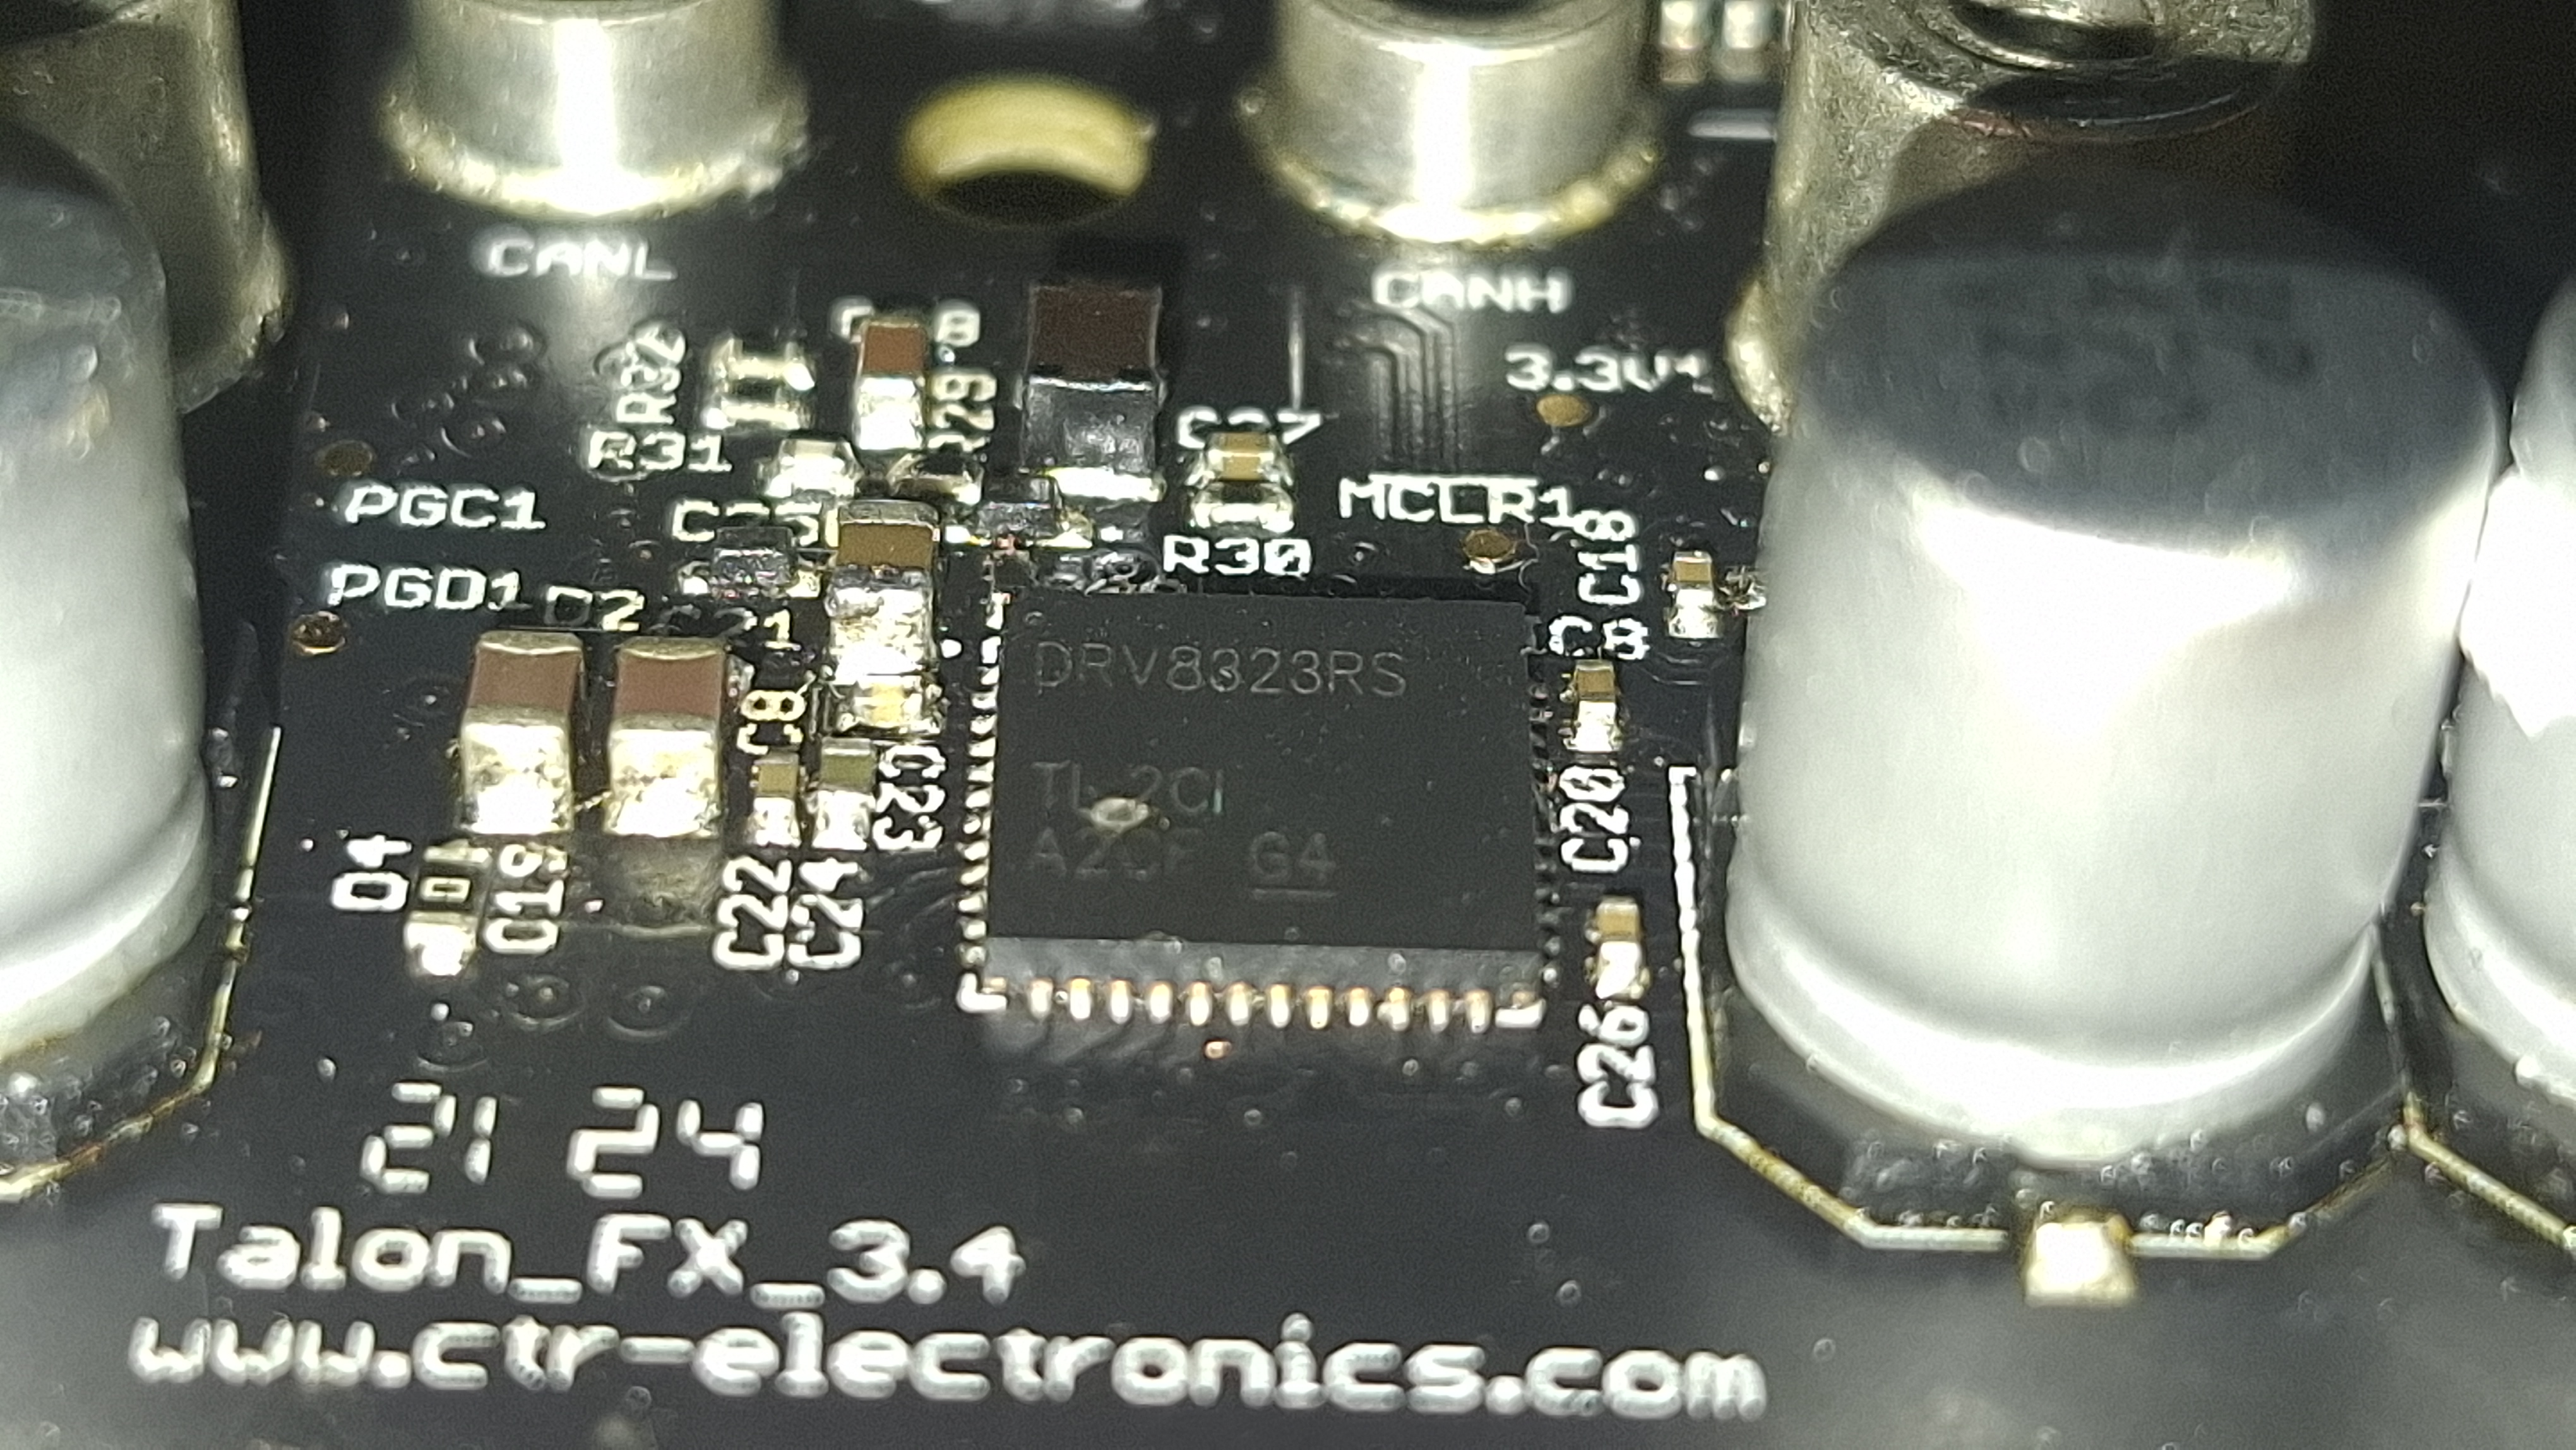 Because of this, we concluded that the motor was damaged by a high-current event, which could have been caused by a short circuit in the wiring or in the motor itself. We are still unsure what caused the short circuit, but whatever the cause, it has never happened to us again. We also haven’t heard of any other teams experiencing the same issue, so we believe it was an isolated event.
Did you try troubleshooting before opening the motor?
Yes. We followed the troubleshooting steps provided by WCP/CTRE, and the motor exhibited the following symptoms:
Eventually the motor started spinning (If helped by hand on the clockwise direction)
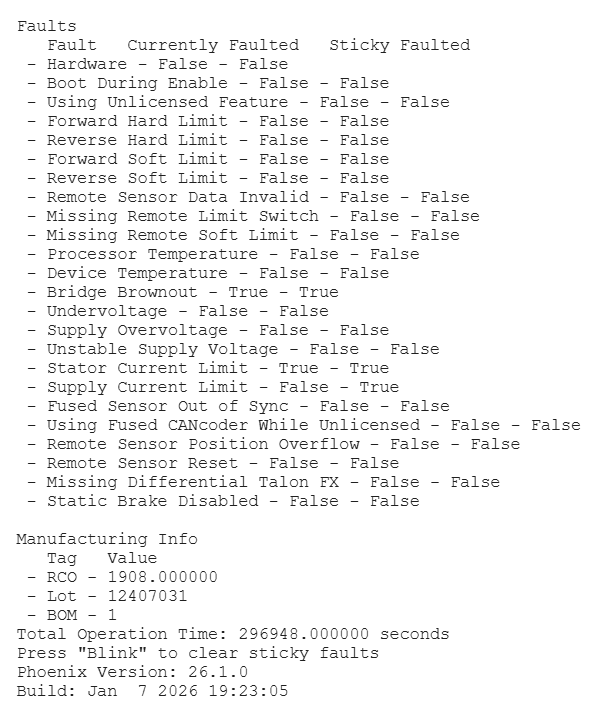
The logged faults were:
Now what?
We contacted WCP/CTRE for support, and they were very helpful in providing us with troubleshooting guides. Unfortunately, they were not able to help us troubleshoot the hardware itself because we were in Panama, and this happened in February, one month before the competition season. That would have made it almost impossible to receive a replacement in time, so we ordered new motors and used those for the remainder of the season.
During the season, on March 23, 2026, WCP released a fix for the Talon FX library that addressed a bug in which “FOC will suddenly commute poorly, resulting in higher than typical current draw and sometimes lower than typical free speed.”
This was very similar to the issue we experienced with our motors. We observed in the Phoenix Tuner logs that the Krakens were drawing very high currents, activating the stator current protection and possibly causing a thermal runaway event that led to the MOSFET failure. We are still unsure whether this was the cause of our failure, but we are very happy that WCP/CTRE released a fix for this issue. Since the fix was released, we have not had any issues with our other motors.