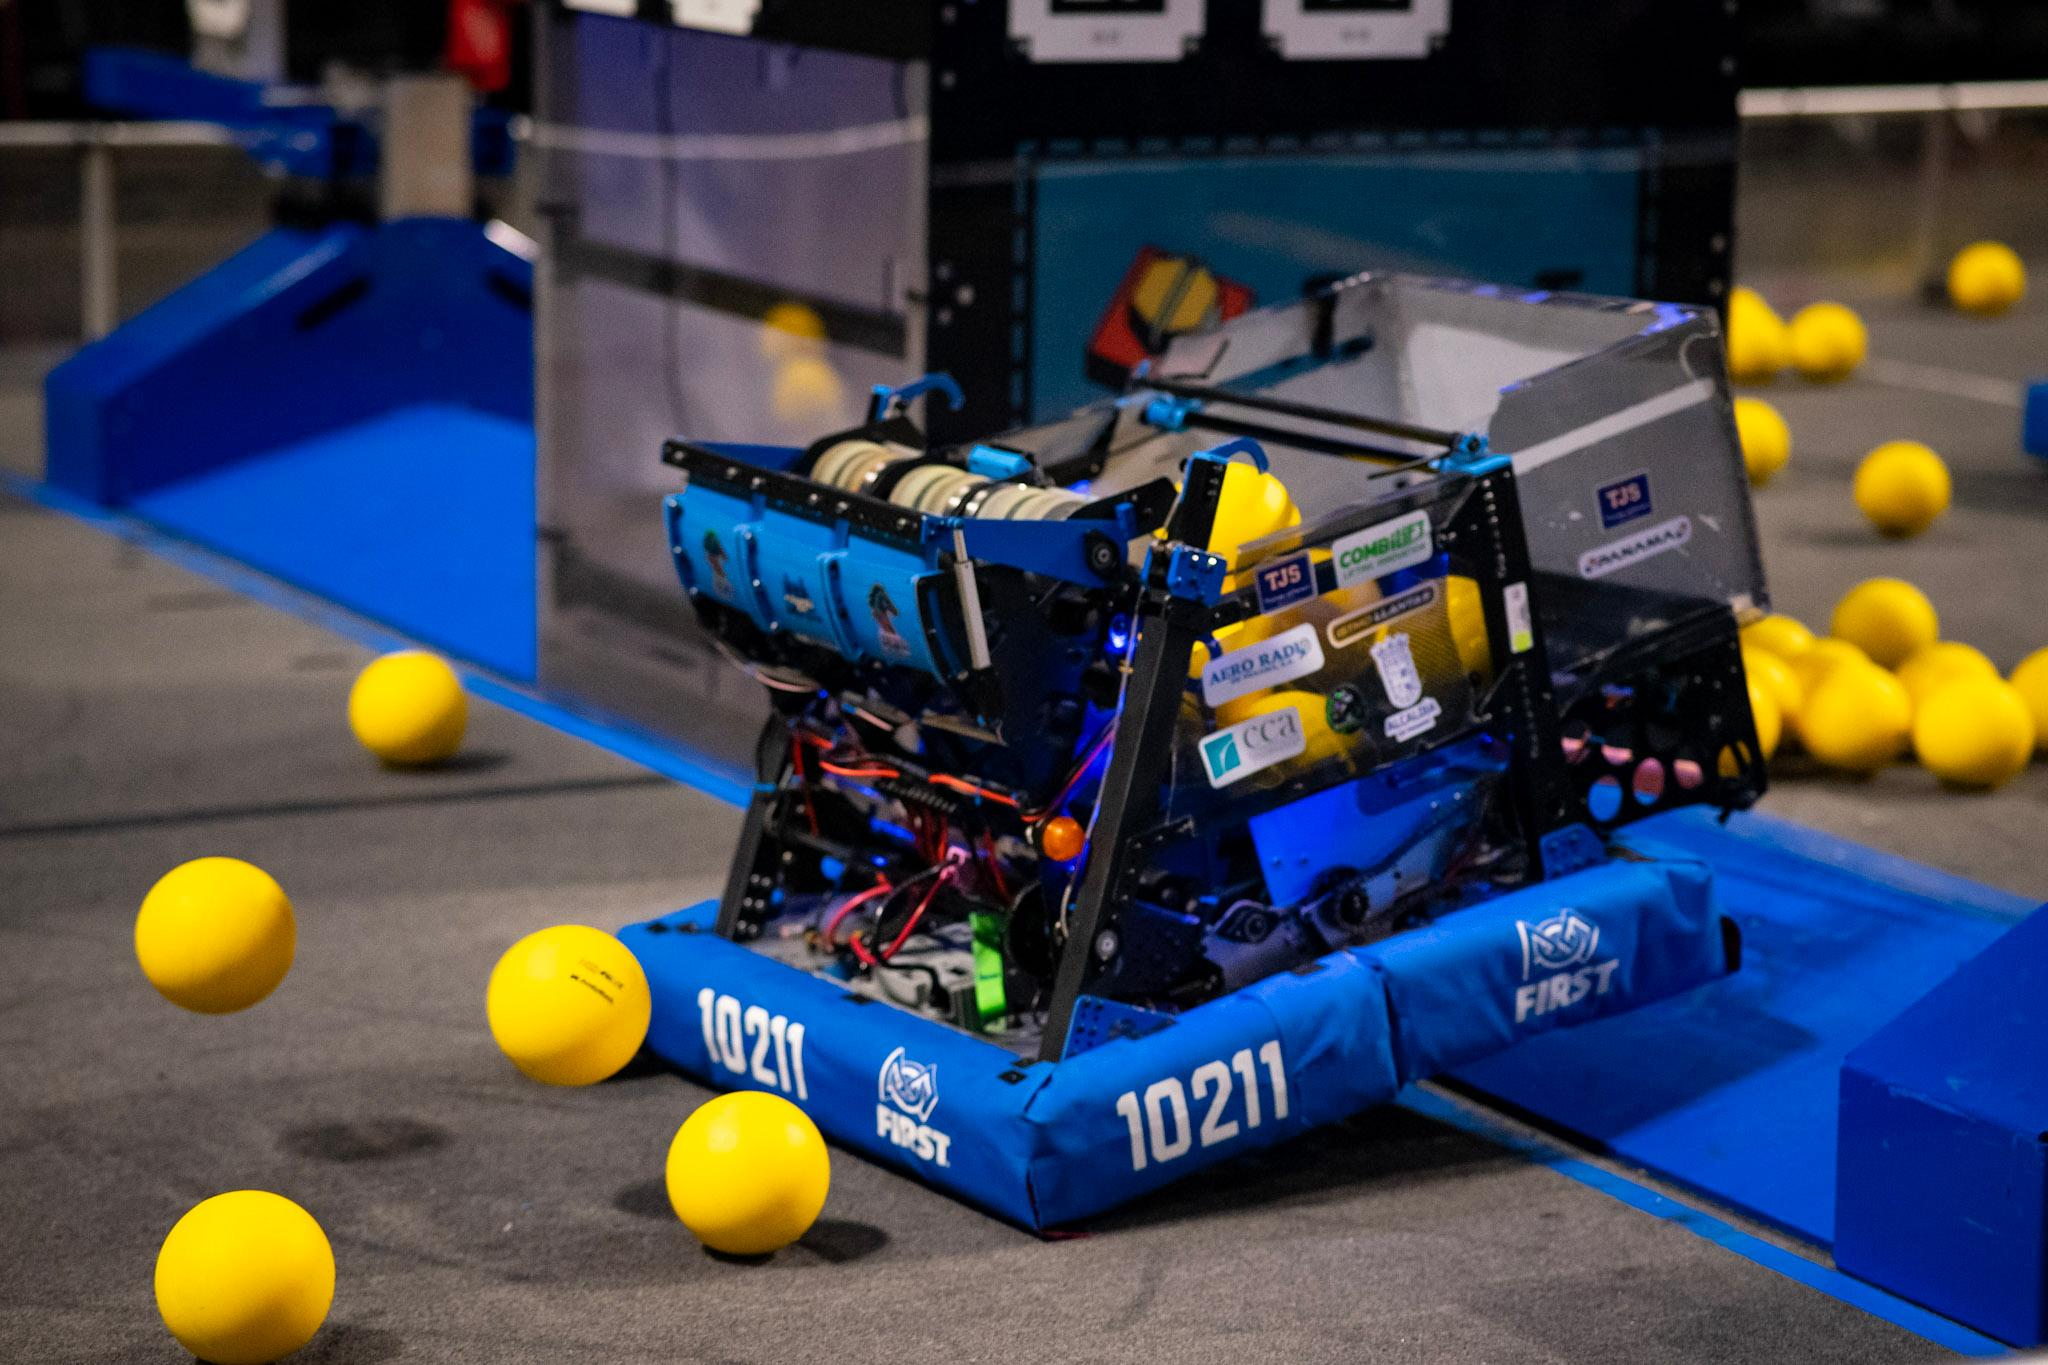
Pegasus is the robot we built for this season, Inspired on WCP 2026 Competitive Concept. Every mechanism started with a simple goal: move game pieces reliably, repeatably, and quickly. The result is a compact machine built around a coordinated intake, shooter, feeder, and swerve drivetrain.
Pegasus was an engineering and cost-reduction challenge for us, we had to consider where to get most of our parts from as most WCP parts were out of stock (intake silicon tubing, floor belts, etc.). We also had the disadvantage of not having an aluminum 6061 plate supplier in our country, so we had to make most parts with heavier 3003 aluminum. Despite these challenges, we were able to build a robot that is competitive and as reliable as the original.
Still, we were able to cut the cost of the robot from almost $12,000 to almost $5,000 with our modified BOM.
Intake
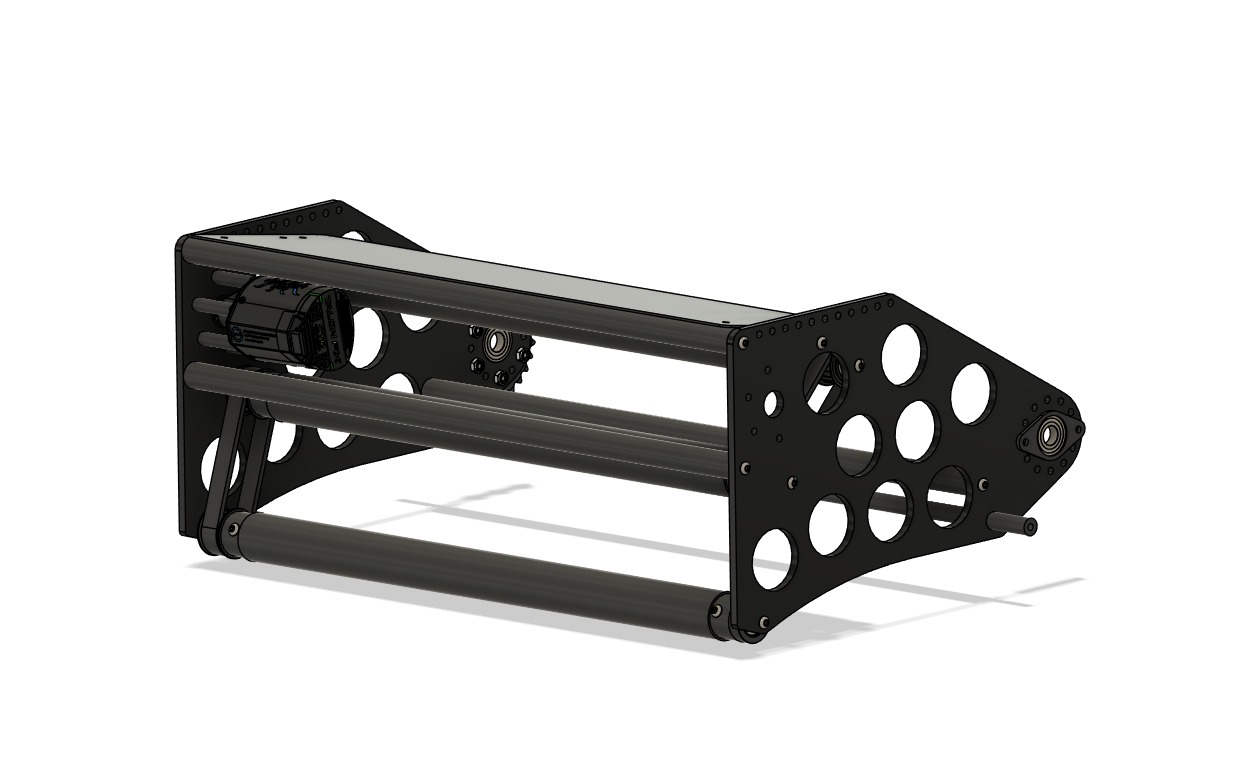
We built Pegasus’s intake from the WCP CC intake kit using 3003 aluminum. To make the structure stiffer and reduce unnecessary weight, we modified the side plates by drilling additional holes.
Shooter
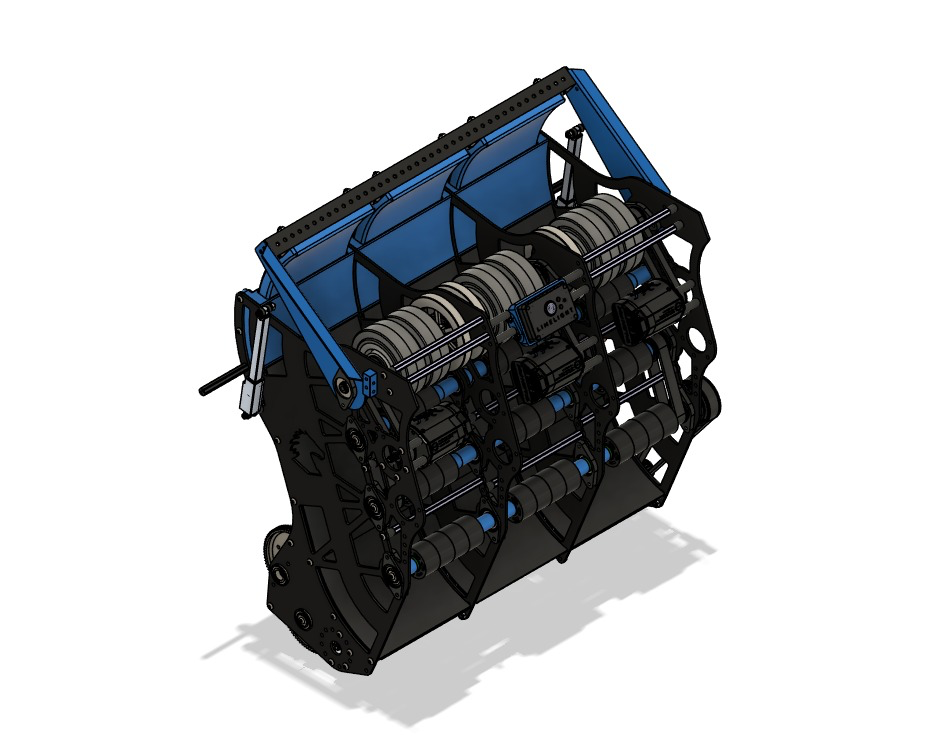
Pegasus uses three WCP CC shooters. We modified the ball compression ratio by using wider Colson wheels, giving the robot a better shot distance and helping it send game pieces where we want them to go.
Feeder
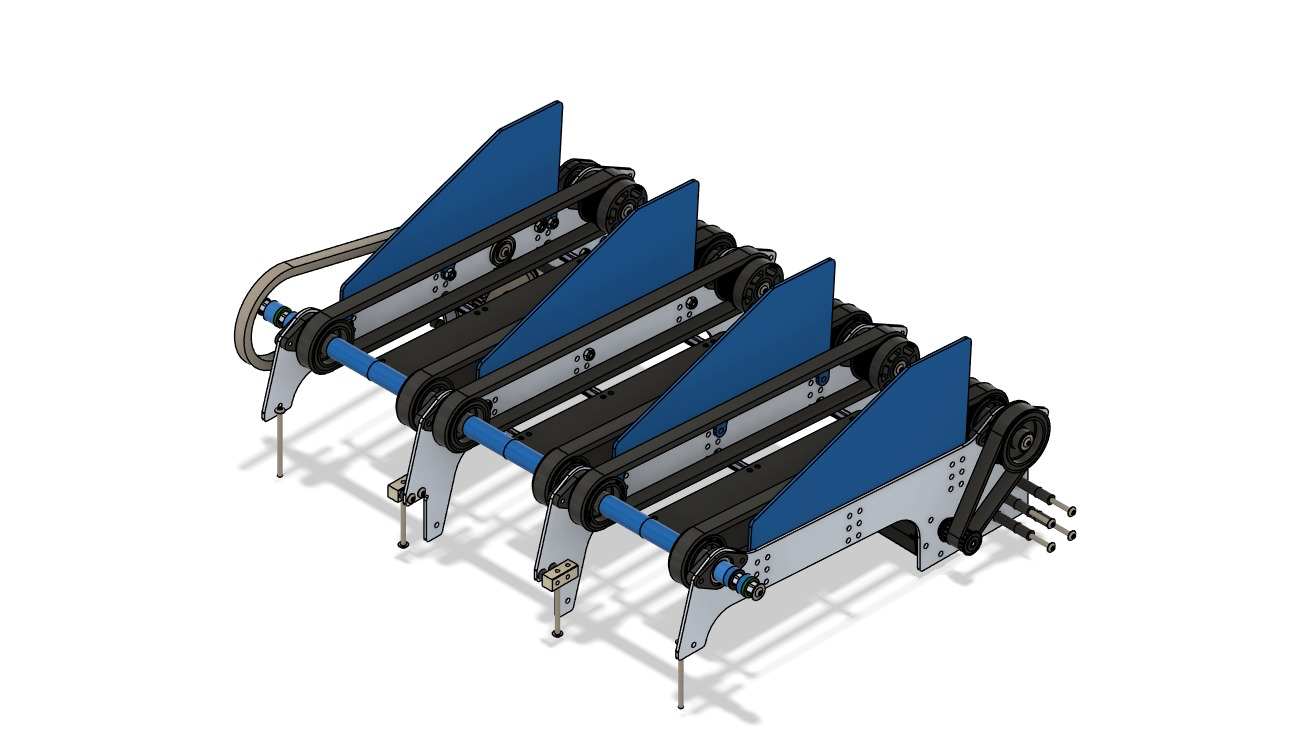
The feeder is a conveyor design driven by a series of pulleys. It sorts and transports balls to the shooter, keeping the handoff between mechanisms controlled and consistent.
Chassis
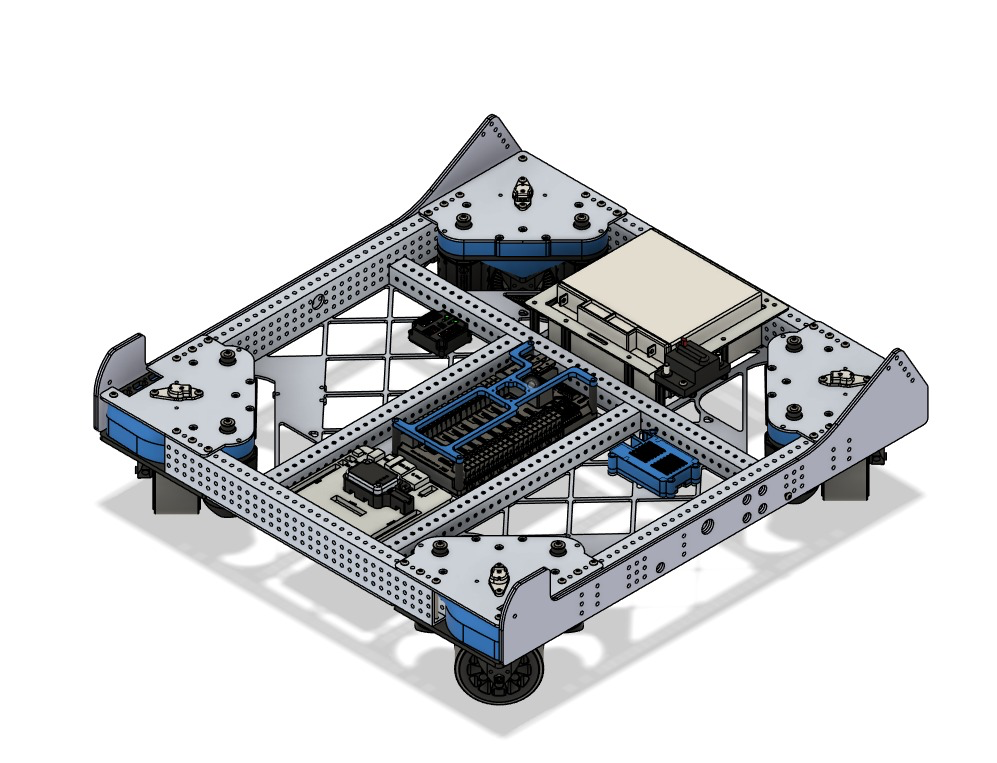
The foundation of Pegasus is a 27-inch by 25.5-inch frame with WCP X2I swerve modules. Kraken X60 motors power the modules, giving the robot the maneuverability and control it needs on the field.
Pegasus is more than a collection of mechanisms. It is the product of many tests, revisions, and conversations in the workshop. We are excited to keep learning from it and learning from all the mistakes that arise with its systems.